This lesson uses: Arduino UNO R3 board, TinkerBlock TK30 Vibration Motor module, jumper wires (or breadboard). Learn to control the motor with digitalWrite() or analogWrite(); outcome: motor vibrates 0.5 s, stops 0.5 s, repeat; optional PWM for strength.
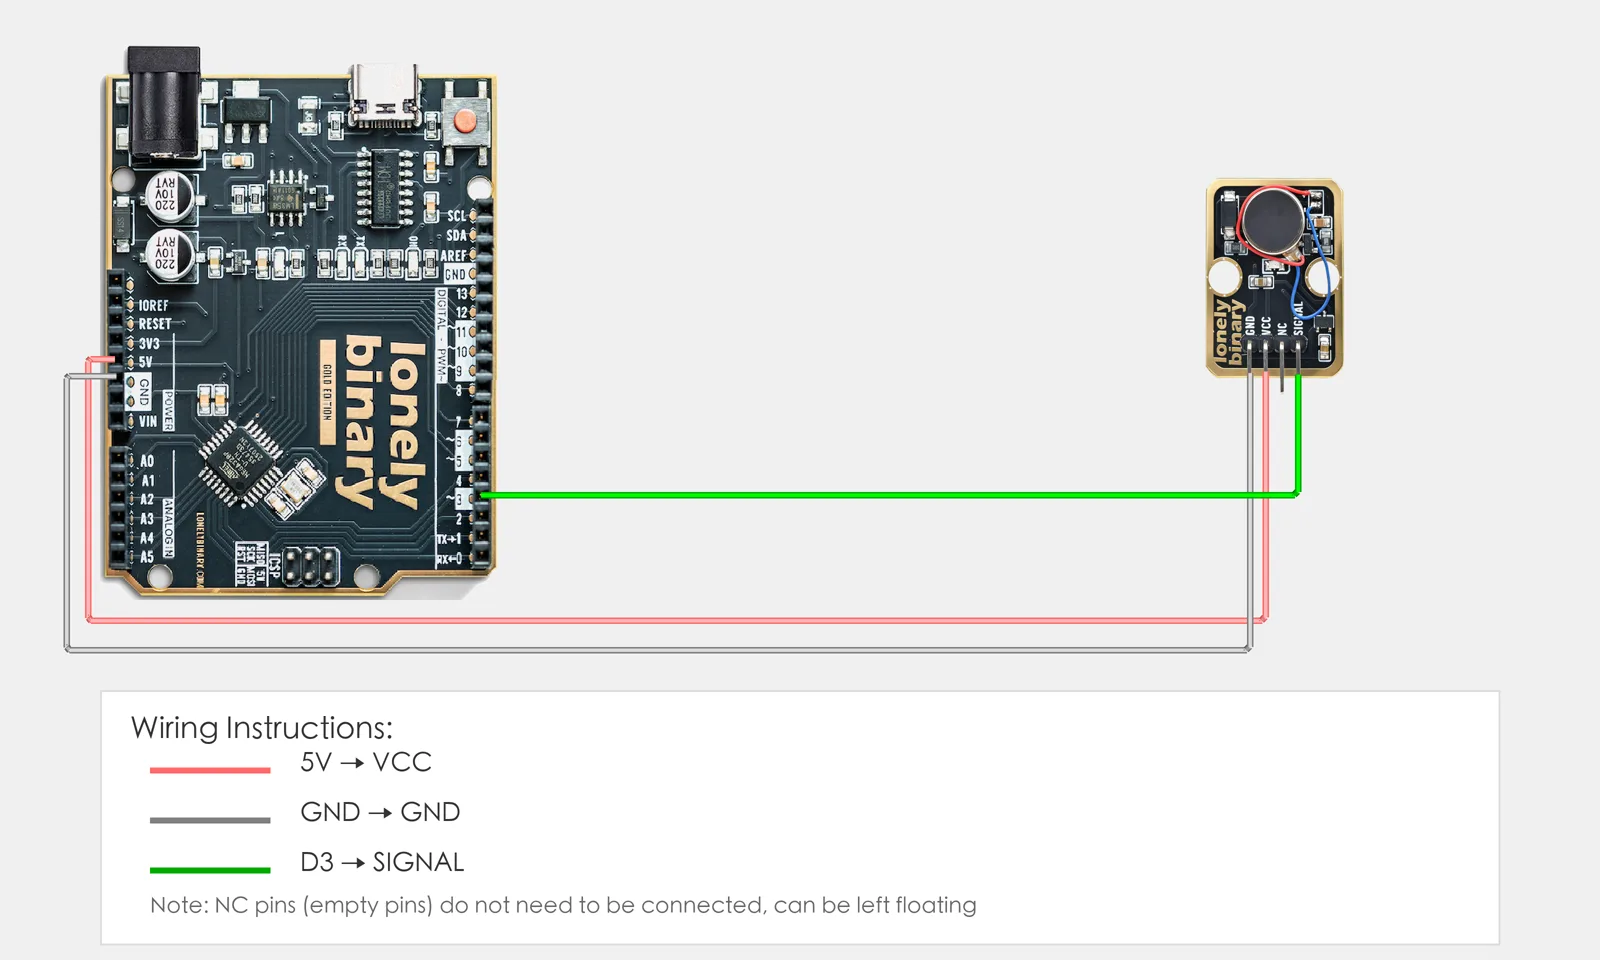
1. Wiring
Connect TK30 Vibration Motor to Arduino:
- GND → Arduino GND
- VCC → Arduino 5V (it feeds the module's own 3.3 V regulator, which powers the motor; the motor gets about 3.3 V from 5V or 3V3 alike)
- SIGNAL → Arduino D3 (PWM pin for speed control)
- NC leave unconnected
2. New sketch
- Arduino IDE: File → New (or Ctrl/Cmd + N) to create a blank sketch
- Confirm board and port are selected (same as Lesson 01)
- Type the code below into the default
setup()andloop()yourself
3. Program structure
Same as last lesson: two fixed blocks setup() and loop().
setup(): Tell the board “pin 3 for motor”; start serial (optional); runs once.loop(): Keep repeating “motor on → wait → motor off → wait → repeat”.
After uploading the motor will vibrate then stop in a loop; for strength control try the PWM code in the comments.
4. Code to write
Type the code below line by line into setup() and loop() (do not copy-paste; typing it yourself helps you remember):
#define MOTOR_PIN 3   // Vibration motor on D3

void setup() {
  pinMode(MOTOR_PIN, OUTPUT);   // D3 output for motor (PWM for speed)
  Serial.begin(9600);
  Serial.println("Vibration motor program started");
}

void loop() {
  // Method 1: digitalWrite (on/off only)
  digitalWrite(MOTOR_PIN, HIGH);   // Vibrate
  Serial.println("Motor vibrating...");
  delay(500);

  digitalWrite(MOTOR_PIN, LOW);    // Stop
  Serial.println("Motor stopped");
  delay(500);

  // Method 2: analogWrite for speed (optional, uncomment to try)
  // analogWrite(MOTOR_PIN, 128);   // 50% duty: may not start from rest
  // delay(500);
  // analogWrite(MOTOR_PIN, 255);   // 100% speed
  // delay(500);
  // analogWrite(MOTOR_PIN, 0);     // Stop
  // delay(500);
}
Program notes
Overall idea: Motor on PWM pin: digitalWrite(HIGH/LOW) = on/off; analogWrite(0–255) = vibration strength (higher duty cycle = stronger). This lesson uses digitalWrite for on/off loop; optionally try the analogWrite lines for speed control.
| Code | In this lesson |
|---|---|
digitalWrite(MOTOR_PIN, HIGH/LOW) | On/off vibration, no speed steps |
analogWrite(MOTOR_PIN, 128) | PWM: 0=off, 255=full, in-between=weaker. Below about 178 a stopped motor may not start: write 255 for 50 ms first |
5. Hands-on
- After entering the code, click Verify (✓) to compile
- Click Upload (→) to upload to the board
- Feel TK30: vibrate 0.5 s, stop 0.5 s, repeat
- Try yourself:
- Uncomment method 2 and use
analogWrite()to control strength - Change
delay()to change on/off time
- Uncomment method 2 and use
Expected result: As in the figure.
Proceed to Lesson 20.
6. Common issues
| Symptom | What to do |
|---|---|
| Motor not vibrating | Check TK30 wiring GND→GND, VCC→5V, SIGNAL→D3 |
| Too weak | Try analogWrite(MOTOR_PIN, 255) for max strength |
Nothing at analogWrite(MOTOR_PIN, 128) | The motor may not start from rest below about 178; write 255 for 50 ms, then 128 |
Edit this page — content/guides/tinkerblock-workshop/19-vibration-motor.mdx
Questions about this product
See what other owners have asked, and read their solutions.
Vibration Motor
Loading discussions…
Discuss this article
Ask about this page. The answer stays here, on the page it belongs to, for whoever hits the same wall next.