
This lesson uses: Arduino UNO R3 board, TinkerBlock TK62 Tilt Sensor module, TinkerBlock TK01 XL LED module, jumper wires (or breadboard). Learn the tilt sensor. Outcome: tip the module so its left edge goes down and the LED turns on; tip it the other way and the LED turns off.
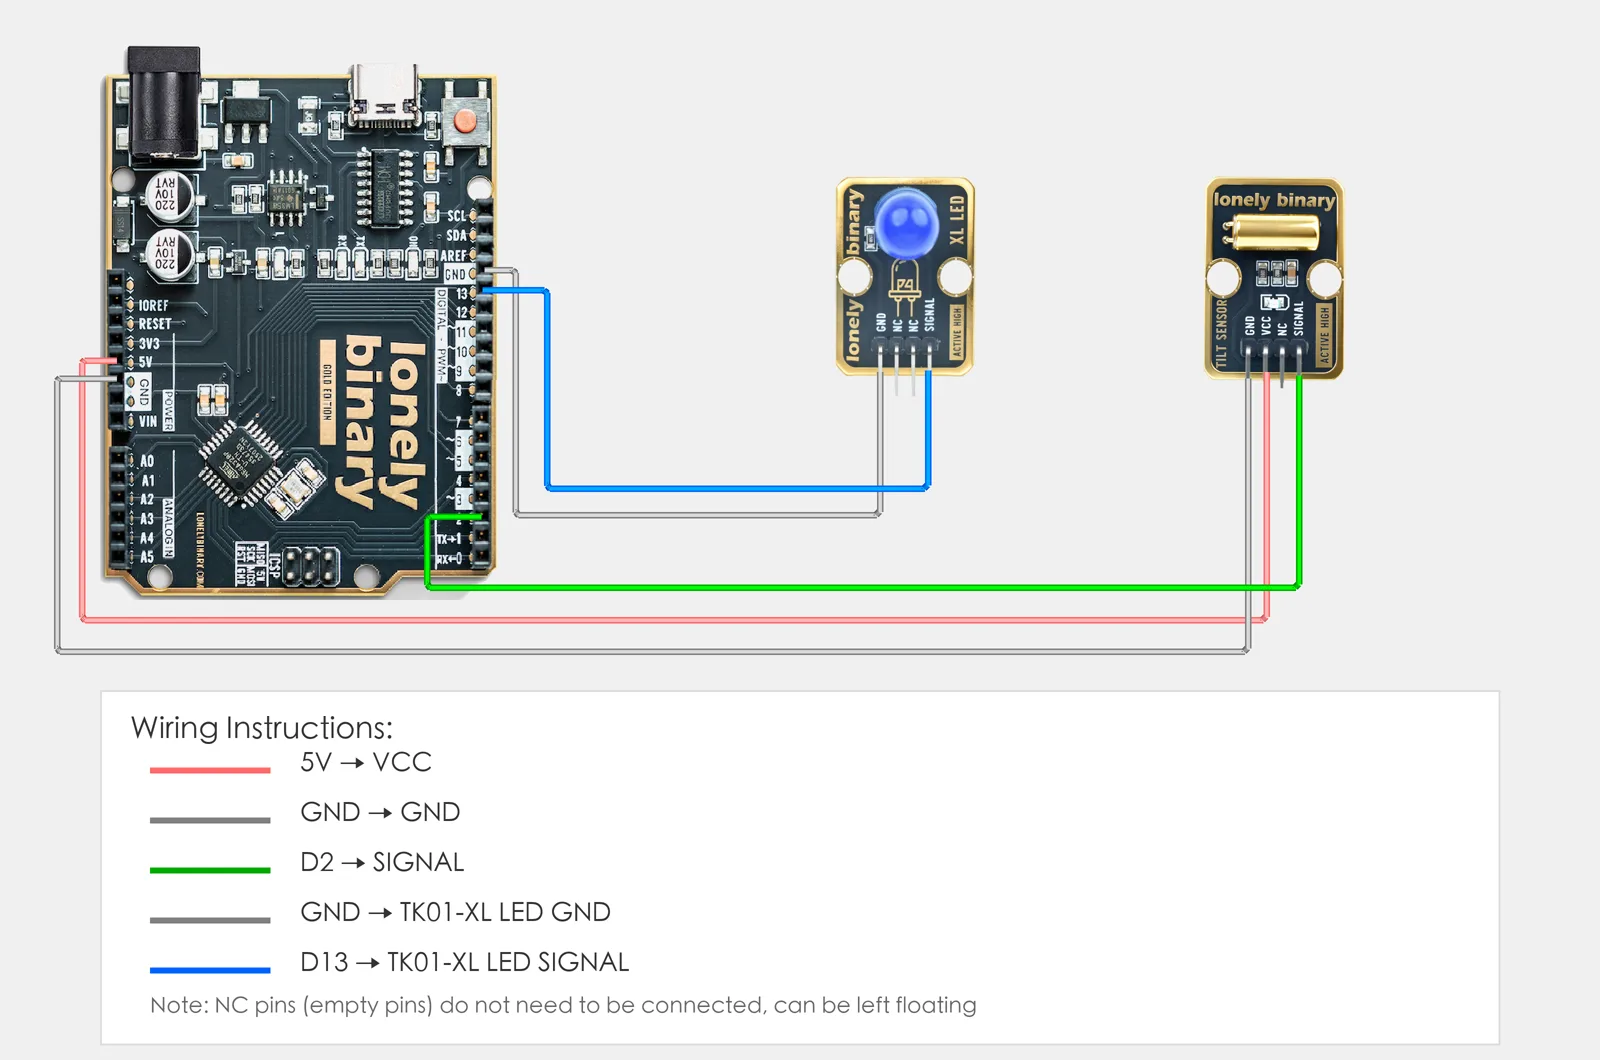
1. Wiring
- TK62 tilt sensor: VCC → 5V, GND → GND, SIGNAL → D2, NC leave unconnected
- TK01 LED: GND → GND, SIGNAL → D13
2. New sketch
- Arduino IDE: File → New (or Ctrl/Cmd + N) to create a blank sketch
- Confirm board and port are selected (same as Lesson 01)
- Type the code below into the default
setup()andloop()yourself
3. Program structure
Same as last lesson: two fixed blocks setup() and loop().
setup(): Tell the board “pin 2 for reading the tilt sensor, pin 13 for the LED”; runs once.loop(): Keep repeating “read pin 2 → if HIGH then LED on, else LED off → short delay”.
Type the code in; tip the module left edge down and the LED turns on, tip it right edge down and it turns off.
4. Code to write
Type the code below line by line into setup() and loop() (do not copy-paste; typing it yourself helps you remember):
// Tilt sensor on D2, LED on D13: output HIGH when tilted, LED on
#define TILT_PIN 2
#define LED_PIN 13

void setup() {
  pinMode(TILT_PIN, INPUT);   // D2 read tilt sensor
  pinMode(LED_PIN, OUTPUT);   // D13 control LED
}

void loop() {
  int state = digitalRead(TILT_PIN);   // TK62 is HIGH when tilted, LOW when level

  if (state == HIGH) {
    digitalWrite(LED_PIN, HIGH);
  } else {
    digitalWrite(LED_PIN, LOW);
  }
  delay(100);   // debounce
}Program notes
Overall idea: Digital input on D2. The ball switch in the can closes when the module's left edge (parts up, header down) is lower than its right, and TK62 outputs HIGH, so the LED is on; with the right edge down it outputs LOW. Lying flat, the can is level and keeps whatever it last read. Same logic as button, touch, collision and other digital sensors.
| Code | In this lesson |
|---|---|
digitalRead(TILT_PIN) | Read the switch: left edge down = HIGH, right edge down = LOW |
if (state == HIGH) | If HIGH then LED on, else off |
5. Hands-on
- After entering the code, click Verify (✓) to compile
- Click Upload (→) to upload to the board
- Tilt detection:
- Try different tilt angles and see when it triggers
Expected result:
Note: If your kit has the TK19 4-Directions Tilt Sensor, you can try it; it can detect tilt in four directions (up, down, left, right).
Proceed to Lesson 11.
6. Common issues
| Symptom | What to do |
|---|---|
| LED does not turn on when tilted | Check TK62 wiring VCC→5V, GND→GND, SIGNAL→D2; check TK01 SIGNAL→D13, GND→GND; tip the left edge down, not the header edge |
| LED always on | The module is resting left edge down, or lying flat after it was; tip it right edge down |
Edit this page — content/guides/tinkerblock-workshop/10-tilt-sensor.mdx
Questions about this product
See what other owners have asked, and read their solutions.
This page covers several products. Choose yours to see the right discussions.
Discuss this article
Ask about this page. The answer stays here, on the page it belongs to, for whoever hits the same wall next.